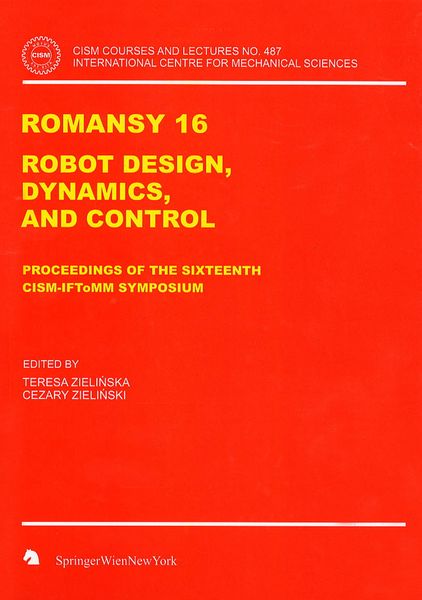
ROMANSY 16 Robot Design, Dynamics and Control
-
- Hardcover
- Taschenbuch ausgewählt
-
Sprache:Englisch
143,99 €
UVP
160,49 €
inkl. gesetzl. MwSt.,
Beschreibung
Produktdetails
Einband
Taschenbuch
Erscheinungsdatum
15.12.2010
Abbildungen
X, 462 p.
Herausgeber
Teresa Zielinska + weitereVerlag
Springer WienSeitenzahl
462
Maße (L/B/H)
24,4/17/2,6 cm
Gewicht
814 g
Auflage
2006
Sprache
Englisch
ISBN
978-3-211-99887-8
Keynote Lectures.- Humanoid Robotics, Culture and Society of Japan.- The Human Frontier: Robotics New Quest and Challenge.- Standardization: A Logical Step in Sustained Space Exploration.- Robot design.- Design and Singularity Criteria of Parallel Manipulators.- L-legs for the Design of Mini and Micro Parallel Compliant Mechanisms.- A singularity free parallel robotic mechanism for aiming antennas and cameras.- Virtual Prototyping of a New Parallel Robot for Milling.- A New Approach for the evaluation of kinematic and static performances of a family of 3-UPU translational manipulators.- Geometric Configuration in Robot Kinematic Design.- Mechanism Performance.- Improvement of Positioning Accuracy of PAMINSA (Parallel Manipulator of the I.N.S.A.).- The Impact of Friction on the Dynamics of Parallel Robotic Manipulators.- Dynamics Aspects of Parallel Anthropomorphic Robots.- Workspace Comparison of Kinematically Redundant Planar Parallel Manipulators.- Dexterity Analysis of Planar Parallel Manipulators.- Stiffness experimental monitoring for WL-16RII Biped Locomotor during walking.- Estimation of Leg Stiffness Parameters of a 6DOF Parallel Mechanism.- Invariant Error Dynamics Controller for a 6-dof Electrohydraulic Stewart Platform.- Motion Planning and Synthesis.- Hyperbolic-linear, Extended Jacobian Inverse Kinematics Algorithm for Doubly Nonholonomic Mobile Manipulators.- Local Variation Method to Determine Cheap Path for Nonholonomic Systems.- Nonlinearity detection and reduction based on unnormalized quasi-velocities.- Motion Planning for Collision Avoidance via Cylindrical Models of Rigid Bodies.- On the Dynamic Stability of Off-Road Vehicles.- Sub-Optimal Motion Planner of Mobile Manipulators in Generalized Point-to-Point Task With Stability Constraint.- A Decoupled Approach to Optimal Time Energy Trajectory Planning of Parallel Kinematic Machines.- Reliable and Adjustable Biped Gait Generation for Slopes Using a GA Optimized Fourier Series Formulation.- A Simplified Method for Generating 3D Gait Using Optimal Sagittal Gait.- Control Methods and Systems.- The Largest Feedback-Linearizable Subsystem of a Class of Wheeled Robots Moving on an Inclined Plane.- Leg Thrust Control for Stabilization of Dynamic Gaits in a Quadruped Robot.- Vehicle Dynamics of Redundant Mobile Robots with Powered Caster Wheels.- Matrix-based Supervisory Controller of Transition-Function Specified Robot Controllers.- Control Architecture for Sensor-Based Two-Handed Manipulation.- Humanoids.- The mechanical improvements of the anthropomorphic flutist robot WF-4RII to increas the sound clarity and to enhance the interactivity with humans.- Mechanical Design of Emotion Expression Humanoid Robot WE-4RII.- The Mechatronic Design of a Human-like Robot Head.- Human Equilibrium Control Principles Implemented into a Biped Humanoid Robot.- Development of a New Humanoid Robot to Realize Various Walking Pattern Using Waist Motions.- From the Human Hand to a Humanoid Hand: Biologically-Inspired Approach for the Development of RoboCasa Hand #1.- Biology and Robotics - Specialized Tools and Methods.- Towards Realistic Surgical Simulation: Biomechanics of Needle Insertion into the Brain.- Robotic System for Femoral & Tibial Osteotomies Assistance.- WL-16RII: Prototype of Biped Walking Wheelchair.- Prosthesis Design by Robotic Approaches Part 1: Metabolical Cost.- Prosthesis Design by Robotic Approaches Part 2: Optimization Approach.- Innovative technologies in robotics.- Sound Source Detection System for Control of an Autonomous Mobile Robot, a Behaviour-BasedApproach.- Development and Control of Wheeled Vehicle that Balances on a Rolling Basketball.- Durability of Large-Deflective Hinges made of Blend Polypropylene used for Molded Pantograph Mechanisms.- Mobile Robots Based on Magnetizable Elastic Elements and Ferrofluids.- A Flexure-Based Electromagnetic Linear Actuator for Nano-Positioning.- An Infrared Location System for Relative Pose Estimation of Robots.-
Ein neues Kapitel für Ihre Bücher
Ein neues Kapitel für Ihre Bücher
Schenken Sie Ihren alten Schätzen ein zweites Leben und erhalten Sie dafür eine Thalia Geschenkkarte.
Noch keine Bewertungen vorhanden
Verfassen Sie die erste Bewertung zu diesem Artikel
Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.
Kurze Frage zu unserer Seite
Vielen Dank für Ihr Feedback
Wir nutzen Ihr Feedback, um unsere Produktseiten zu verbessern. Bitte haben Sie Verständnis, dass wir Ihnen keine Rückmeldung geben können. Falls Sie Kontakt mit uns aufnehmen möchten, können Sie sich aber gerne an unseren Kund*innenservice wenden.
zum Kundenservice