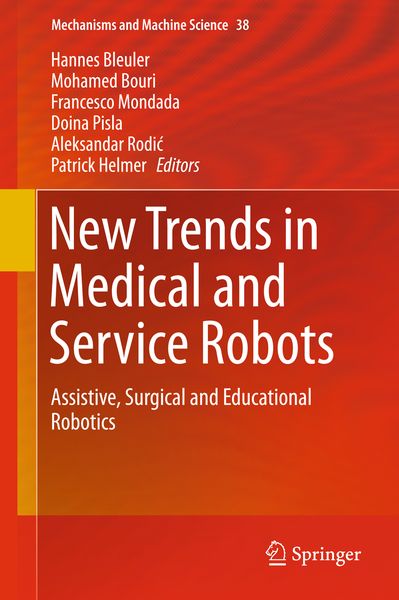
New Trends in Medical and Service Robots Assistive, Surgical and Educational Robotics
-
- Hardcover ausgewählt
- Taschenbuch
- eBook
-
Sprache:Englisch
-
Auflage:1st ed. 2016
95,99 €
UVP
106,99 €
inkl. gesetzl. MwSt.,
Beschreibung
Produktdetails
Einband
Gebundene Ausgabe
Erscheinungsdatum
13.11.2015
Abbildungen
IX, 254 p.
Herausgeber
Hannes Bleuler + weitereVerlag
SpringerSeitenzahl
254
Maße (L/B/H)
24,1/16/2 cm
Gewicht
513 g
Auflage
1st ed. 2016
Sprache
Englisch
ISBN
978-3-319-23831-9
Medical and Service Robotics integrate the most recent achievements in mechanics, mechatronics, computer science, haptic and teleoperation devices together with adaptive control algorithms.
The book includes topics such as surgery robotics, assist devices, rehabilitation technology, surgical instrumentation and Brain-Machine Interface (BMI) as examples for medical robotics. Autonomous cleaning, tending, logistics, surveying and rescue robots, and elderly and healthcare robots are typical examples of topics from service robotics.
This is the Proceedings of the Third International Workshop on Medical and Service Robots, held in Lausanne, Switzerland in 2014. It presents an overview of current research directions and fields of interest. It is divided into three sections, namely 1) assistive and rehabilitation devices; 2) surgical robotics; and 3) educational and service robotics. Most contributions are strongly anchored on collaborations between technical and medical actors, engineers, surgeons and clinicians. Biomedical robotics and the rapidly growing service automation fields have clearly overtaken the “classical” industrial robotics and automatic control centered activity familiar to the older generation of roboticists.
Ein neues Kapitel für Ihre Bücher
Ein neues Kapitel für Ihre Bücher
Schenken Sie Ihren alten Schätzen ein zweites Leben und erhalten Sie dafür eine Thalia Geschenkkarte.
Noch keine Bewertungen vorhanden
Verfassen Sie die erste Bewertung zu diesem Artikel
Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.
Kurze Frage zu unserer Seite
Vielen Dank für Ihr Feedback
Wir nutzen Ihr Feedback, um unsere Produktseiten zu verbessern. Bitte haben Sie Verständnis, dass wir Ihnen keine Rückmeldung geben können. Falls Sie Kontakt mit uns aufnehmen möchten, können Sie sich aber gerne an unseren Kund*innenservice wenden.
zum Kundenservice