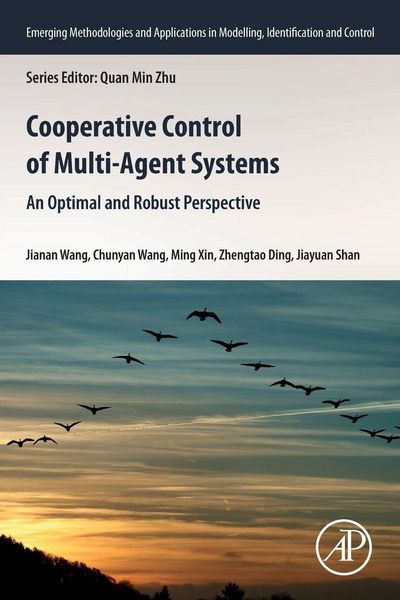
Cooperative Control of Multi-Agent Systems
-
- Taschenbuch ausgewählt
- eBook
-
Sprache:Englisch
178,99 €
inkl. gesetzl. MwSt.,
Beschreibung
Produktdetails
Einband
Taschenbuch
Erscheinungsdatum
26.03.2020
Verlag
Elsevier Science & TechnologySeitenzahl
260
Maße (L/B/H)
22,9/15,2/1,4 cm
Gewicht
354 g
Sprache
Englisch
ISBN
978-0-12-820118-3
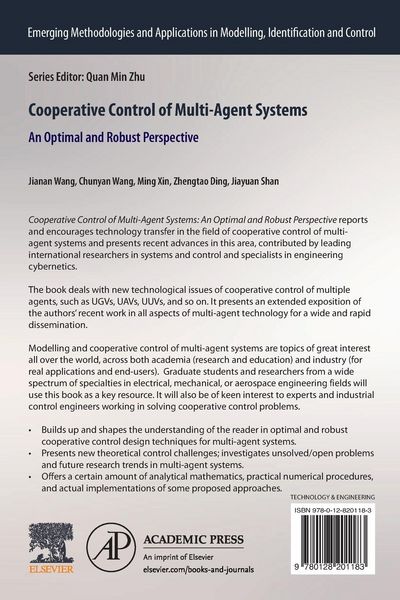
Cooperative Control of Multi-Agent Systems: An Optimal and Robust Perspective reports and encourages technology transfer in the field of cooperative control of multi-agent systems. The book deals with UGVs, UAVs, UUVs and spacecraft, and more. It presents an extended exposition of the authors' recent work on all aspects of multi-agent technology. Modelling and cooperative control of multi-agent systems are topics of great interest, across both academia (research and education) and industry (for real applications and end-users). Graduate students and researchers from a wide spectrum of specialties in electrical, mechanical or aerospace engineering fields will use this book as a key resource.
Ein neues Kapitel für Ihre Bücher
Ein neues Kapitel für Ihre Bücher
Schenken Sie Ihren alten Schätzen ein zweites Leben und erhalten Sie dafür eine Thalia Geschenkkarte.
Noch keine Bewertungen vorhanden
Verfassen Sie die erste Bewertung zu diesem Artikel
Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.
Kurze Frage zu unserer Seite
Vielen Dank für Ihr Feedback
Wir nutzen Ihr Feedback, um unsere Produktseiten zu verbessern. Bitte haben Sie Verständnis, dass wir Ihnen keine Rückmeldung geben können. Falls Sie Kontakt mit uns aufnehmen möchten, können Sie sich aber gerne an unseren Kund*innenservice wenden.
zum Kundenservice