















































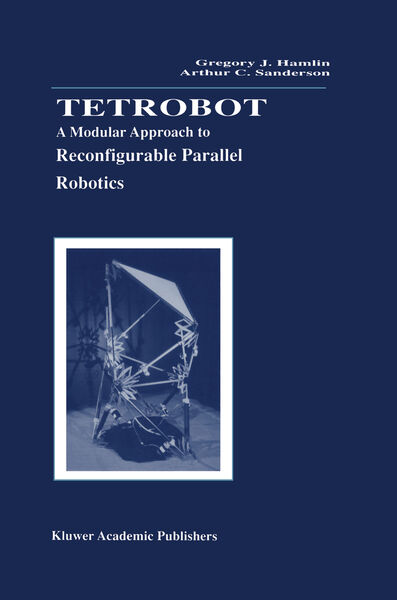
Tetrobot A Modular Approach to Reconfigurable Parallel Robotics
-
- Hardcover ausgewählt
- Taschenbuch
- eBook
-
Sprache:Englisch
138,99 €
UVP
160,49 €
inkl. gesetzl. MwSt.,
Beschreibung
Produktdetails
Einband
Gebundene Ausgabe
Erscheinungsdatum
31.10.1997
Abbildungen
XIII, 182 p.
Verlag
Springer UsSeitenzahl
182
Maße (L/B/H)
23,4/15,6/1,3 cm
Gewicht
458 g
Auflage
1998 edition
Sprache
Englisch
ISBN
978-0-7923-8025-2
Robotic systems are characterized by the intersection of computer intelligence with the physical world. This blend of physical reasoning and computational intelligence is well illustrated by the Tetrobot study described in this book.
Tetrobot: A Modular Approach to Reconfigurable Parallel Robotics
describes a new approach to the design of robotic systems. The Tetrobot approach utilizes modular components which may be reconfigured into many different mechanisms which are suited to different applications. The Tetrobot system includes two unique contributions: a new mechanism (a multilink spherical joint design), and a new control architecture based on propagation of kinematic solutions through the structure. The resulting Tetrobot system consists of fundamental components which may be mechanically reassembled into any modular configuration, and the control architecture will provide position control of the resulting structure.
A prototype Tetrobot system has been built and evaluated experimentally. Tetrobot arms, platforms, and walking machines have been built and controlled in a variety of motion and loading conditions.
The Tetrobot system has applications in a variety of domains where reconfiguration, flexibility, load capacity, and failure recovery are important aspects of the task.
A number of key research directions have been opened by the Tetrobot research activities. Continuing topics of interest include: development of a more distributed implementation of the computer control architecture, analysis of the dynamics of the Tetrobot system motion for improved control of high-speed motions, integration of sensor systems to control the motion and shape of the high-dimensionality systems, and exploration of self-reconfiguration of the system.
Tetrobot: A Modular Approach to Reconfigurable Parallel Robotics
will be of interest to research workers, specialists and professionals in the areas of robotics, mechanical systems and computer engineering.
Ein neues Kapitel für Ihre Bücher
Ein neues Kapitel für Ihre Bücher
Schenken Sie Ihren alten Schätzen ein zweites Leben und erhalten Sie dafür eine Thalia Geschenkkarte.
Noch keine Bewertungen vorhanden
Verfassen Sie die erste Bewertung zu diesem Artikel
Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.
Kurze Frage zu unserer Seite
Vielen Dank für Ihr Feedback
Wir nutzen Ihr Feedback, um unsere Produktseiten zu verbessern. Bitte haben Sie Verständnis, dass wir Ihnen keine Rückmeldung geben können. Falls Sie Kontakt mit uns aufnehmen möchten, können Sie sich aber gerne an unseren Kund*innenservice wenden.
zum Kundenservice