















































KI-Beratung Beta

Gutscheinbedingungen

Gültig bis 11.11.2026 | Gültig für Spielzeug, Filme, Musik, Software, Games, Geschenke & Trends, Schreibwaren, Hörbücher und Hörbuch-Downloads (außer Abo & Shelfies), gebrauchte Bücher, nicht preisgebundene Bücher und Kalender | Einlösbar unter thalia.de und in der Thalia App | Click & Collect nur mit Online-Zahlung (Paypal/Kreditkarte) vorab | Einzelne Artikel können ausgeschlossen sein | Nicht kombinierbar mit anderen Gutscheinen oder Preisaktionen | Nur einmal pro Einkauf einlösbar | Gutschein wird auf max. 500€ Bestellwert angerechnet | Keine Barauszahlung | Digitale Hörbücher nur für Android  | Nicht gültig für preisgebundene Artikel (aufgrund der Buchpreisbindung sind Gutscheine nicht auf Bücher, eBooks, Presse einlösbar), tolino eReader & Zubehör, Abonnements & Flatrates, Geschenkkarten, Versandkosten und Services

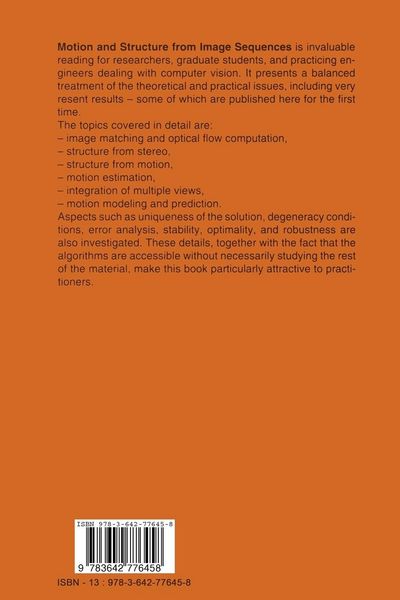
  • Produktbild: Motion and Structure from Image Sequences
  • Produktbild: Motion and Structure from Image Sequences
Band 29

Motion and Structure from Image Sequences

97,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

08.12.2011

Abbildungen

XV, 444 p.

Verlag

Springer Berlin

Seitenzahl

444

Maße (L/B/H)

23,5/15,5/2,5 cm

Gewicht

698 g

Auflage

Softcover reprint of the original 1st ed. 1993

Sprache

Englisch

ISBN

978-3-642-77645-8

Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

08.12.2011

Abbildungen

XV, 444 p.

Verlag

Springer Berlin

Seitenzahl

444

Maße (L/B/H)

23,5/15,5/2,5 cm

Gewicht

698 g

Auflage

Softcover reprint of the original 1st ed. 1993

Sprache

Englisch

ISBN

978-3-642-77645-8

Herstelleradresse

Springer-Verlag KG
Sachsenplatz 4-6
1201 Wien
AT

Email: ProductSafety@springernature.com

Ein neues Kapitel für Ihre Bücher

Ein neues Kapitel für Ihre Bücher

Schenken Sie Ihren alten Schätzen ein zweites Leben und erhalten Sie dafür eine Thalia Geschenkkarte.

Jetzt verkaufen
Jetzt verkaufen

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

  • Produktbild: Motion and Structure from Image Sequences
  • Produktbild: Motion and Structure from Image Sequences
  • 1. Introduction.- 1.1 Formulation of the Problem.- 1.2 Overview of Recent Progress.- 1.3 Bibliographical Notes.- 2. Image Matching.- 2.1 Approaches to Establishing Correspondences.- 2.2 An Approach to Image Matching.- 2.3 Algorithm.- 2.4 Motion and Structure Computation.- 2.5 Refinements.- 2.6 Examples.- 2.7 Summary.- 2.8 Bibliographical Notes.- 3. Two-View Analysis.- 3.1 Some Basic Issues.- 3.2 An Algorithm.- 3.3 Error Estimation.- 3.4 Error Analysis.- 3.5 Performance.- 3.6 Summary.- 3.7 Bibliographical Notes.- Appendix 3.A Perturbation of Eigenspace.- Appendix 3.B Quaternions.- Appendix 3.C Alternative Fitting.- 4. Optimization.- 4.1 Motivations.- 4.2 Stability of Linear Algorithms.- 4.3 Maximum Likelihood Estimation.- 4.4 A Two-Step Approach and Computation.- 4.5 Minimum Variance Estimation.- 4.6 Error Estimation and Error Bounds.- 4.7 Batch and Sequential Methods.- 4.9 Summary.- 4.10 Bibliographical Notes.- Appendix 4.A Decomposability.- Appendix 4.B Weights.- Appendix 4.C Triangulation with Noise.- Appendix 4.D Matrix Derivatives.- Appendix 4.E Cramér-Rao Bound.- 5. Planar Scenes.- 5.1 Planar Scene as a Degenerate Case.- 5.2 Motion from a Plane.- 5.3 Inherent Uniqueness.- 5.4 Examples.- 5.5 Conclusions.- 5.6 Bibliographical Notes.- Appendix 5.A Conditions on the Rank of A.- Appendix 5.B Two Solutions from F.- Appendix 5.C Plane-Perceivable Surfaces.- Appendix 5.D Condition on Consistent Normals.- Appendix 5.E Two-View Algorithm.- Appendix 5.F Error Estimation.- 6. From Line Correspondences.- 6.1 Lines as Features.- 6.2 Solution and Algorithm.- 6.3 Degeneracy.- 6.4 Optimization.- 6.5 Simulations.- 6.6 Conclusions and Discussions.- 6.7 Bibliographical Notes.- Appendix 6.A Ranks.- Appendix 6.B Unique Consistent Assignment.- Appendix 6.C Degeneracy.- Appendix 6.DDistinct Locations Are Necessary.- Appendix 6.E Alternative Degeneracy Condition.- 7. Stereo.- 7.1 Stereo Camera Systems.- 7.2 Stereo Triangulation.- 7.3 Closed-Form Solution.- 7.4 Iterative Optimal Solution.- 7.5 Outliers and Robust Estimators.- 7.6 Examples.- 7.7 Without Stereo Correspondences.- 7.8 Long Image Sequences.- 7.9 Conclusions.- 7.10 Bibliographical Notes.- Appendix 7.A MWCC Theorem.- Appendix 7.B Least-Squares Matrix Fitting.- 8. Motion Modeling and Prediction.- 8.1 Coherence of Motion.- 8.2 The LCAM Model.- 8.3 Estimation and Prediction.- 8.4 Monocular Vision.- 8.5 Optimization.- 8.6 Experimental Examples.- 8.7 Summary.- 8.8 Bibliographical Notes.- Appendix 8.A Solution of Coefficient Equations.- Appendix 8.B Rotation without Precession.- Appendix 8.C Singularity of the Matrix.- References.